Rover Swerve
2025-2026 | Mechanical Design / Systems Integration
CAD Viewer
Overview
Traditional fixed-angle drivetrains have limited maneuverability, particularly laterally. Increasing agility during navigation, terrain traversal, and precision manipulation is a huge asset. While swerve drive is often considered the ideal fix, there is no single standard design among engineering teams.
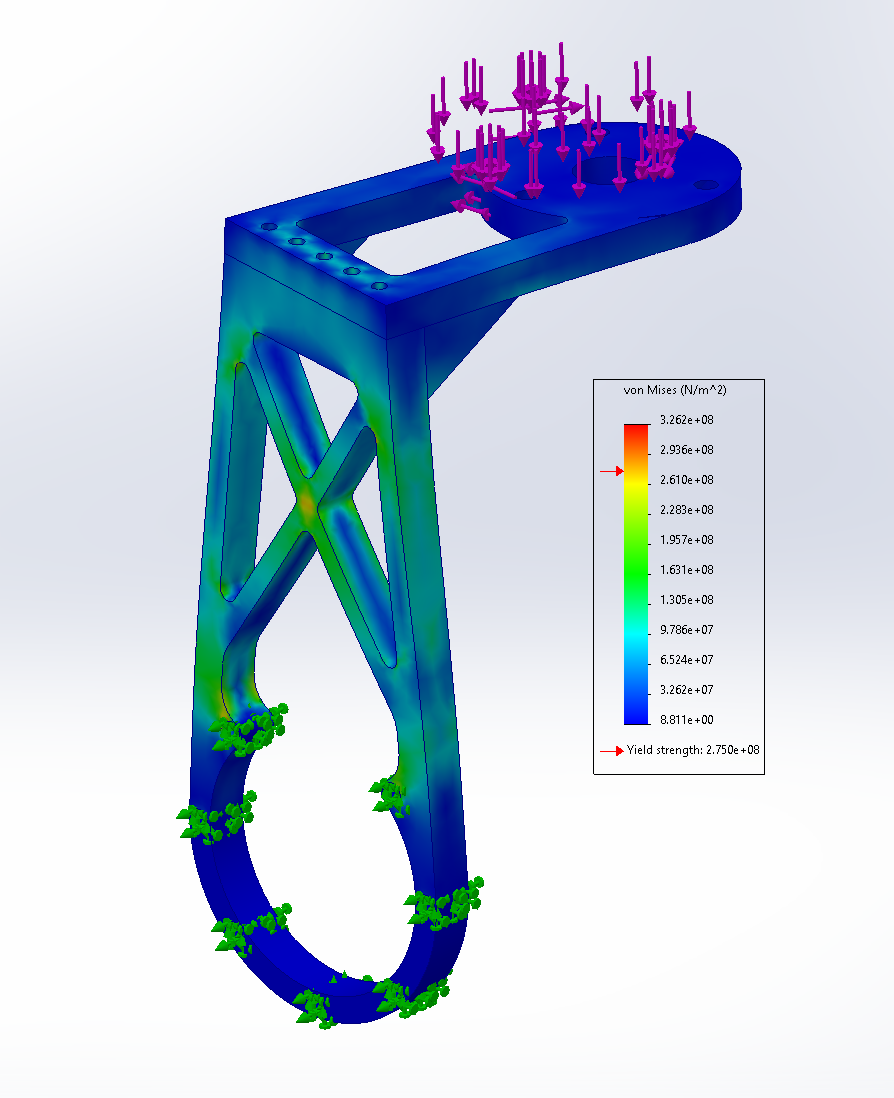
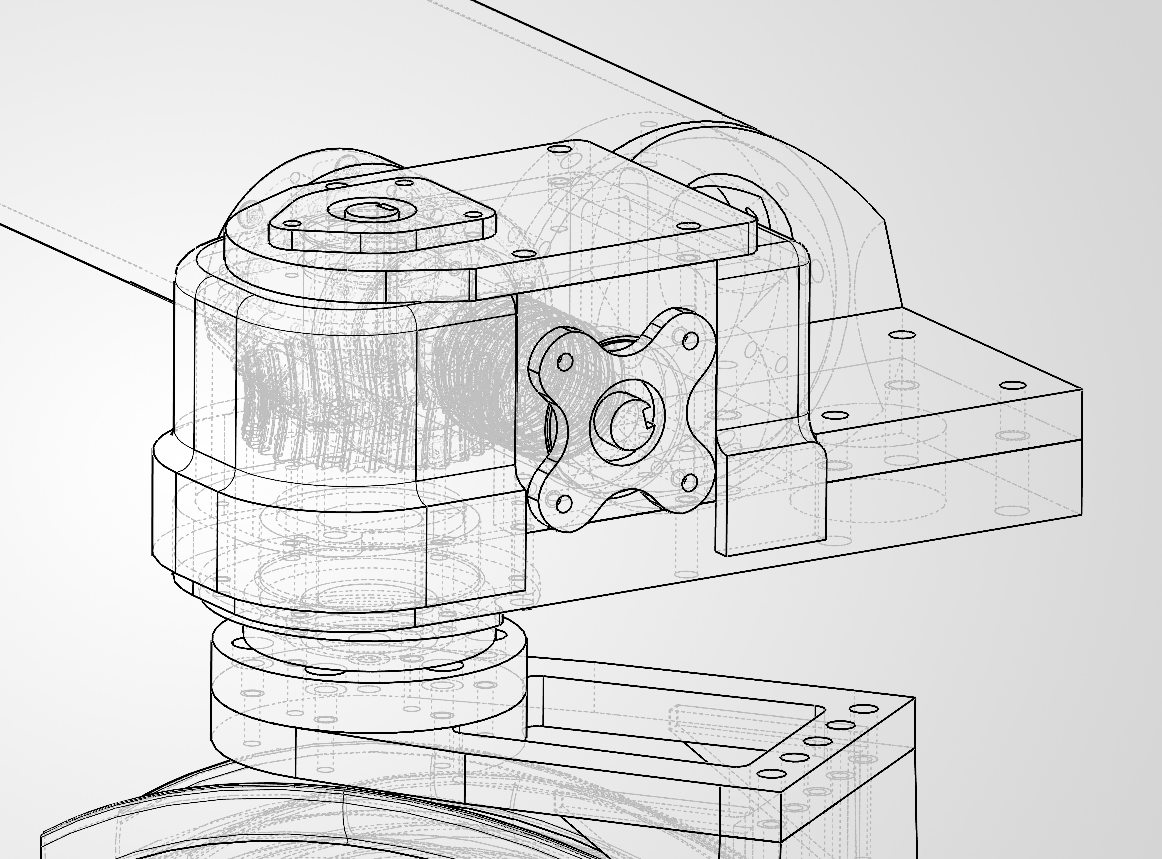
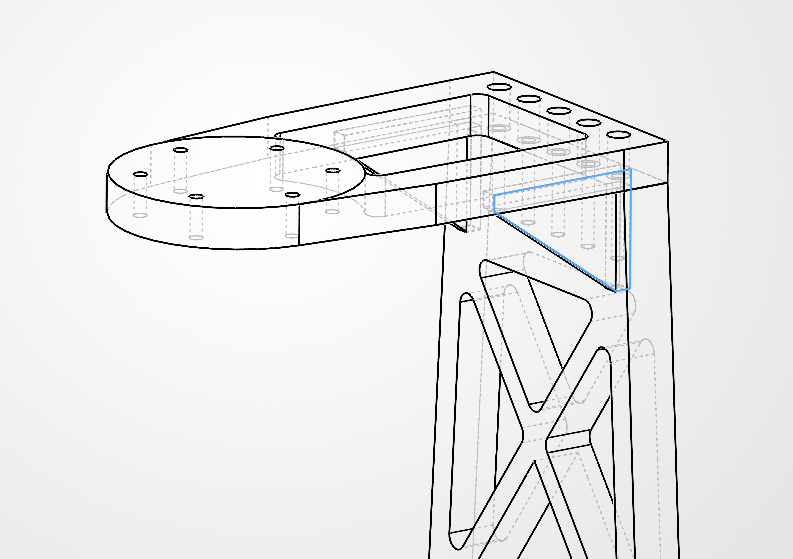
To solve this, I designed a compact swerve module built to fit within a 1 m x 1 m starting rover configuration, add no more than 1.5 kg per module, and deliver at least 70 Nm of rotational torque. I chose a worm drive for its high gear ratio—which allowed for a smaller, lighter brushless DC motor—and its natural resistance to backdriving. I ran numerous iterations on the mounting brackets to shave off excess material while retaining strength and minimizing deflection in key load areas. Each component has machinist-ready drawings. Additionally, I designed the 3D-printed enclosure to seal tightly against dust in harsh field environments while still allowing easy access to the drive gears for greasing and cleaning through a top panel.
Key Deliverables & Specs
- Fits within 1 m x 1 m starting envelope
- Module mass less than 1.5 kg
- Rotational torque output greater than 70 Nm
Tools Used
- SolidWorks (3D CAD & Iterative FEA)
- BLDC Motors & Drive Systems
Images